Welcome!
I’m a Robotics Researcher at ITA (Aragón Institute of Technology) and an Adjunct Professor at the University of Zaragoza.
I completed my PhD in Robotics at the University of Zaragoza in 2024, under the supervision of Prof. José A. Castellanos, and carried out a research stay at the Massachusetts Institute of Technology (MIT) in early 2023 with Prof. Luca Carlone. My PhD research focused on Active SLAM, developing new graph-theoretic and DRL-based approaches for robotic decision-making. Since mid-2023, I have been working at ITA on projects in robotic perception, navigation, and 3D reconstruction, while also teaching robotics and automation courses at the University of Zaragoza.
My research interests lie at the intersection of Active SLAM, 3D scene understanding, and Deep Learning, with a focus on bridging perception and action in autonomous robotic systems. I am particularly interested in:
- Active perception and autonomous exploration
- Deep reinforcement learning and vision-language-action models for robotic decision-making
- Uncertainty modeling and propagation in SLAM
- Graph-based SLAM
- High-level semantic understanding of 3D environments
- Compact graph representations for SLAM and 3D scene understanding
- Data-driven models for scene understanding and place recognition
News
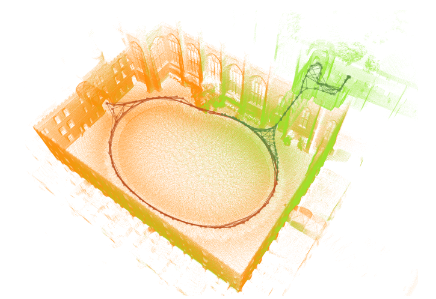
When to map?
Aion will be presented at ICRA 2026!
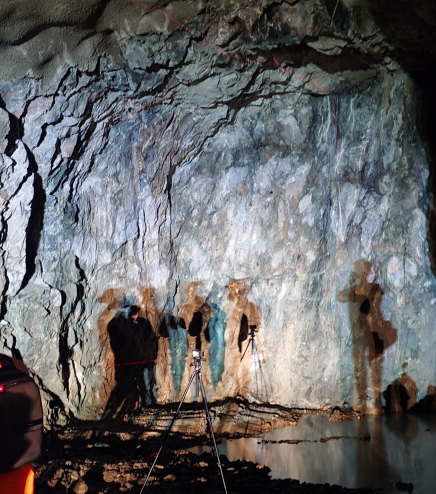
Autonomous robotics in underground mines
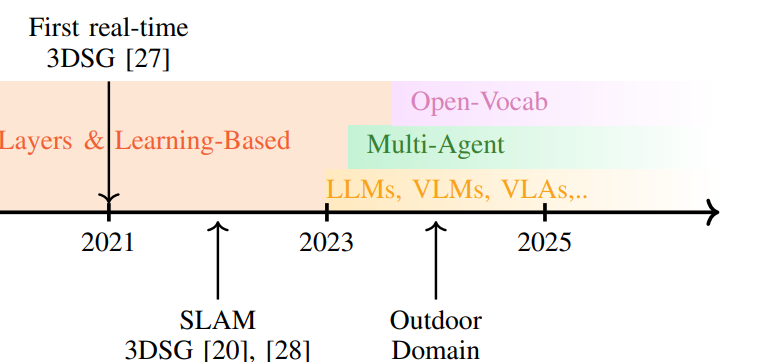
New survey on 3D Scene Graphs